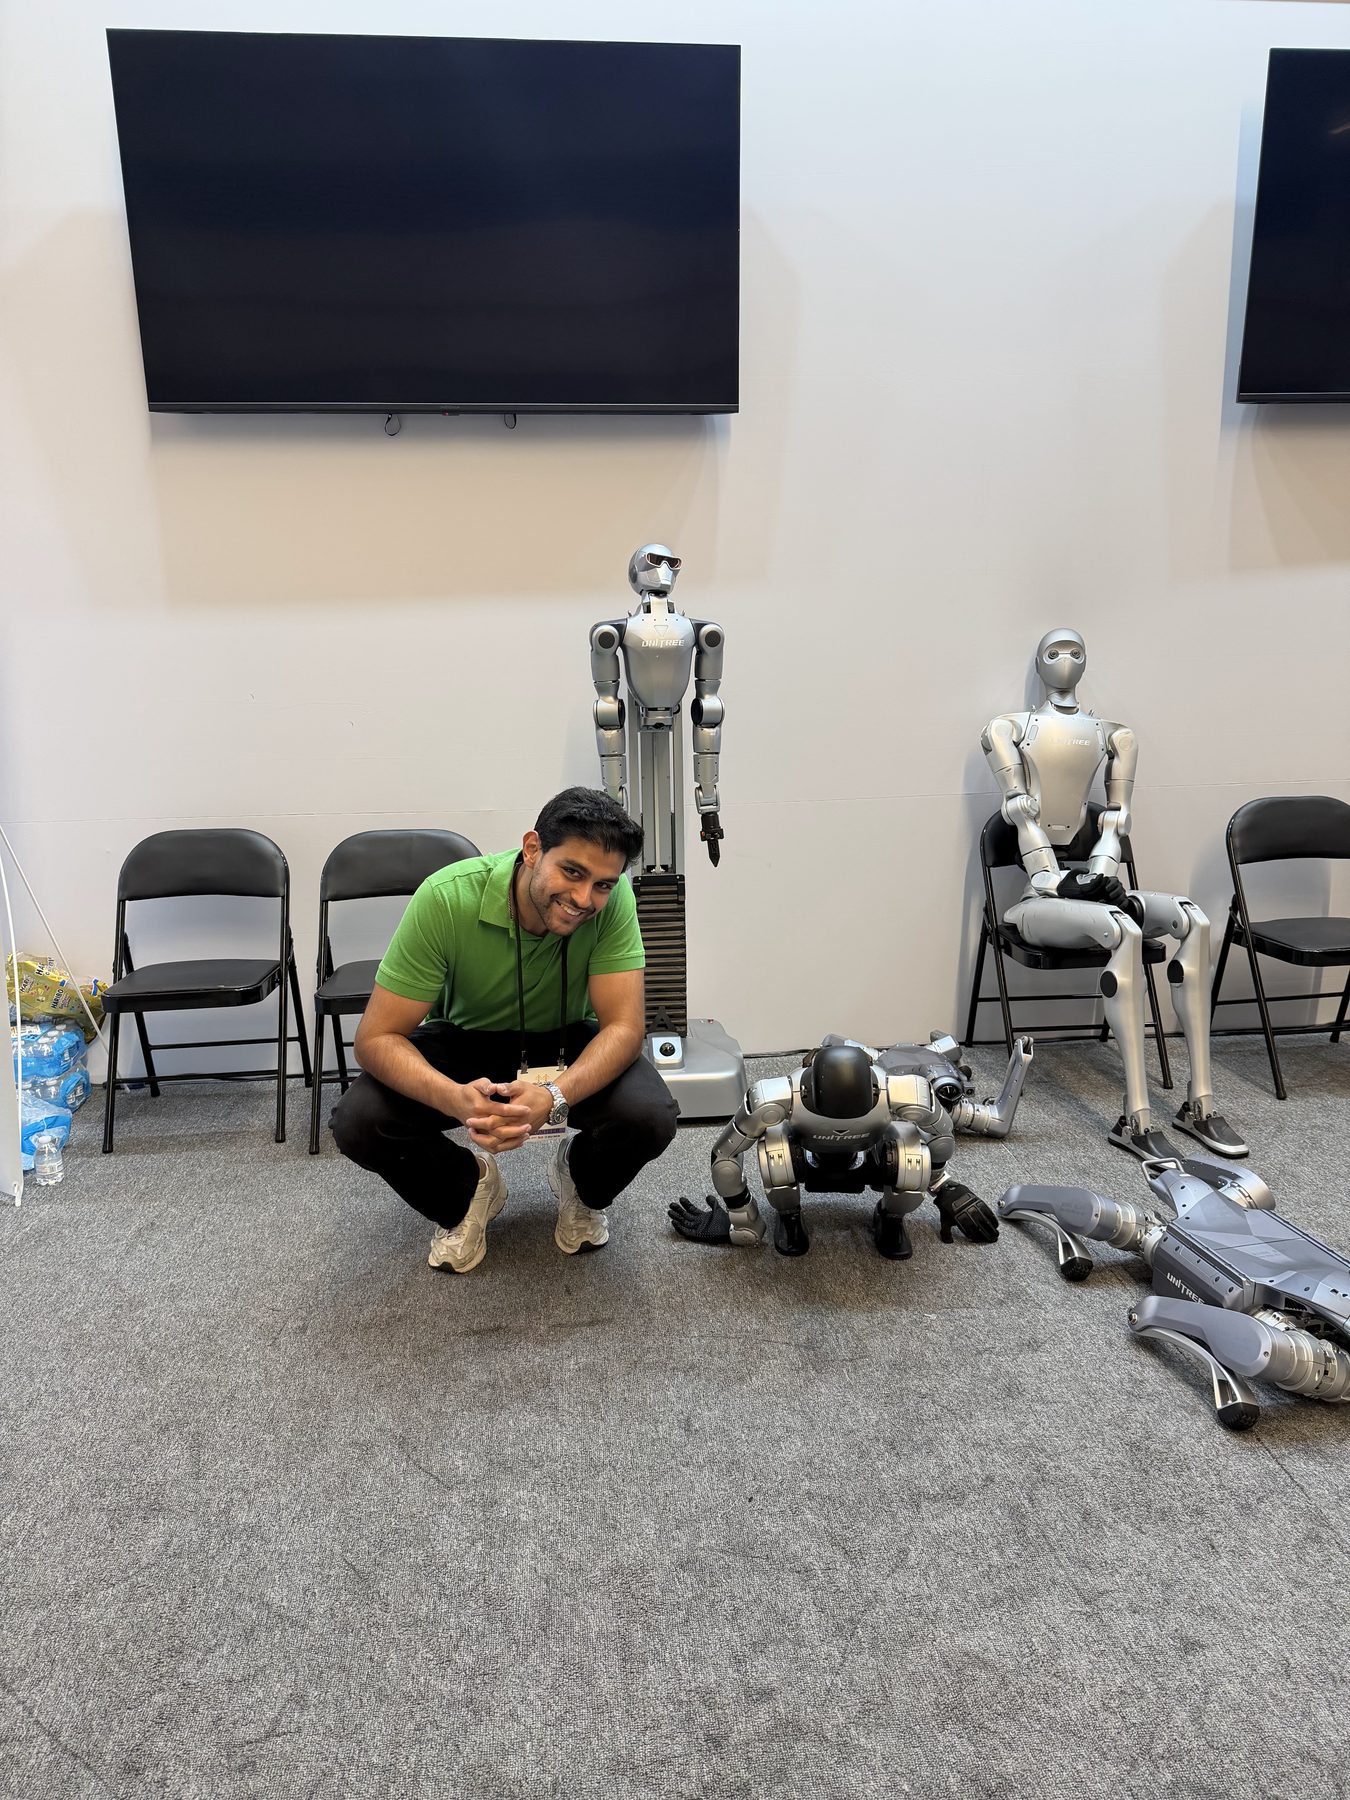
Shayaan Shaikh

MS in Robotics Carnegie Mellon University

Shayaan Shaikh

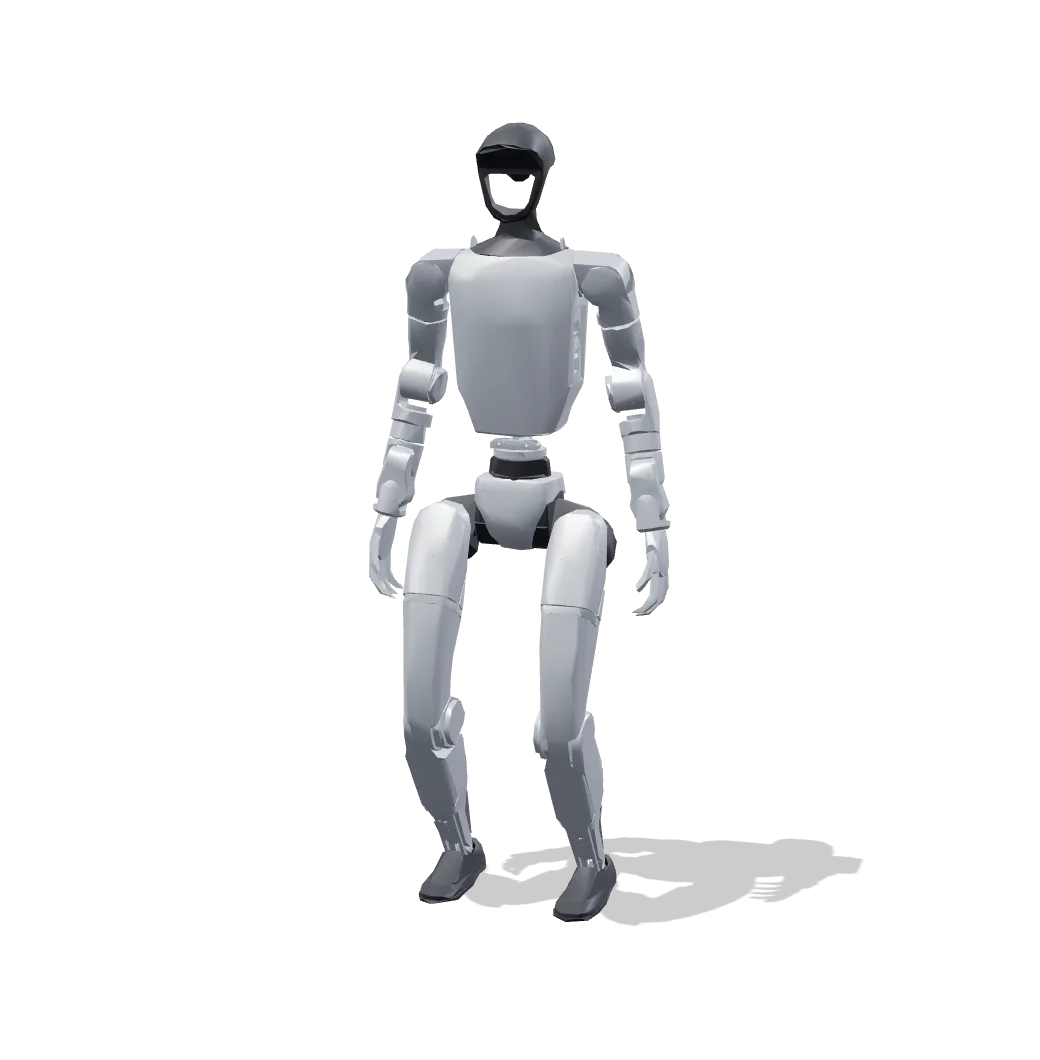
Drag the robot to push it around, or tap it for a shove. It keeps its balance by stepping toward its capture point, the spot where it could still come to a stop.

Center of mass Capture point Support polygon 0 steps · 0 falls

About

I'm a first-year MS in Robotics student at Carnegie Mellon University, co-advised by Dr. Ji Zhang (Z-Lab) and Dr. Jonathan Francis (Robot Learning Lab, Bosch Center for AI and CMU). I work on contact-rich, whole-body loco-manipulation skills for humanoids. Right now I'm focused on getting them to lift objects of what I like to call non-trivial weight (heavy!!!).

Before CMU, I studied aerospace engineering at Toronto Metropolitan University (TMU), graduating with distinction and second in my program. There I wrote a survey of machine learning for aerial manipulation with Dr. Farrokh Janabi-Sharifi, tracked space debris with on-orbit star trackers with Dr. John Enright, and spent a year on the Canadarm3 program at MDA Space.

Interestshumanoid robotics · loco-manipulation · robot learning · whole-body control

News

  • Volunteering at IROS 2026 in Pittsburgh.

  • Started the MS in Robotics at CMU and joined Z-Lab and the Robot Learning Lab as a graduate research assistant.

  • Submitted our survey, Machine Learning in Aerial Manipulation, to Robotics and Autonomous Systems.

  • Graduated from TMU with a B.Eng. in Aerospace Engineering, with distinction.

  • Received the Dennis Mock Student Leadership Award, both program-wide and faculty-wide.

  • Presented our space debris tracking work at CASI ASTRO 2024 in Toronto.

Research

Current

Humanoid loco-manipulation

Graduate Research Assistant · Z-Lab, CMU Robotics Institute, with Dr. Ji Zhang · Robot Learning Lab, Bosch Center for AI and CMU, with Dr. Jonathan Francis · Aug 2026 – present

  • Deployed NVIDIA's SONIC whole-body controller in MuJoCo as the base for a humanoid skill library.
  • Building non-prehensile whole-body skills for heavy payloads, such as lifting a box by hugging it to the torso.
  • Developing compliant-interaction skills for contact-rich tasks, such as opening a car door and sitting in the seat.
  • Whole-body control
  • MuJoCo
  • mjlab
  • Isaac Lab
  • Unitree G1
  • RoboParty RP1

Videos will be posted here as the work comes together.

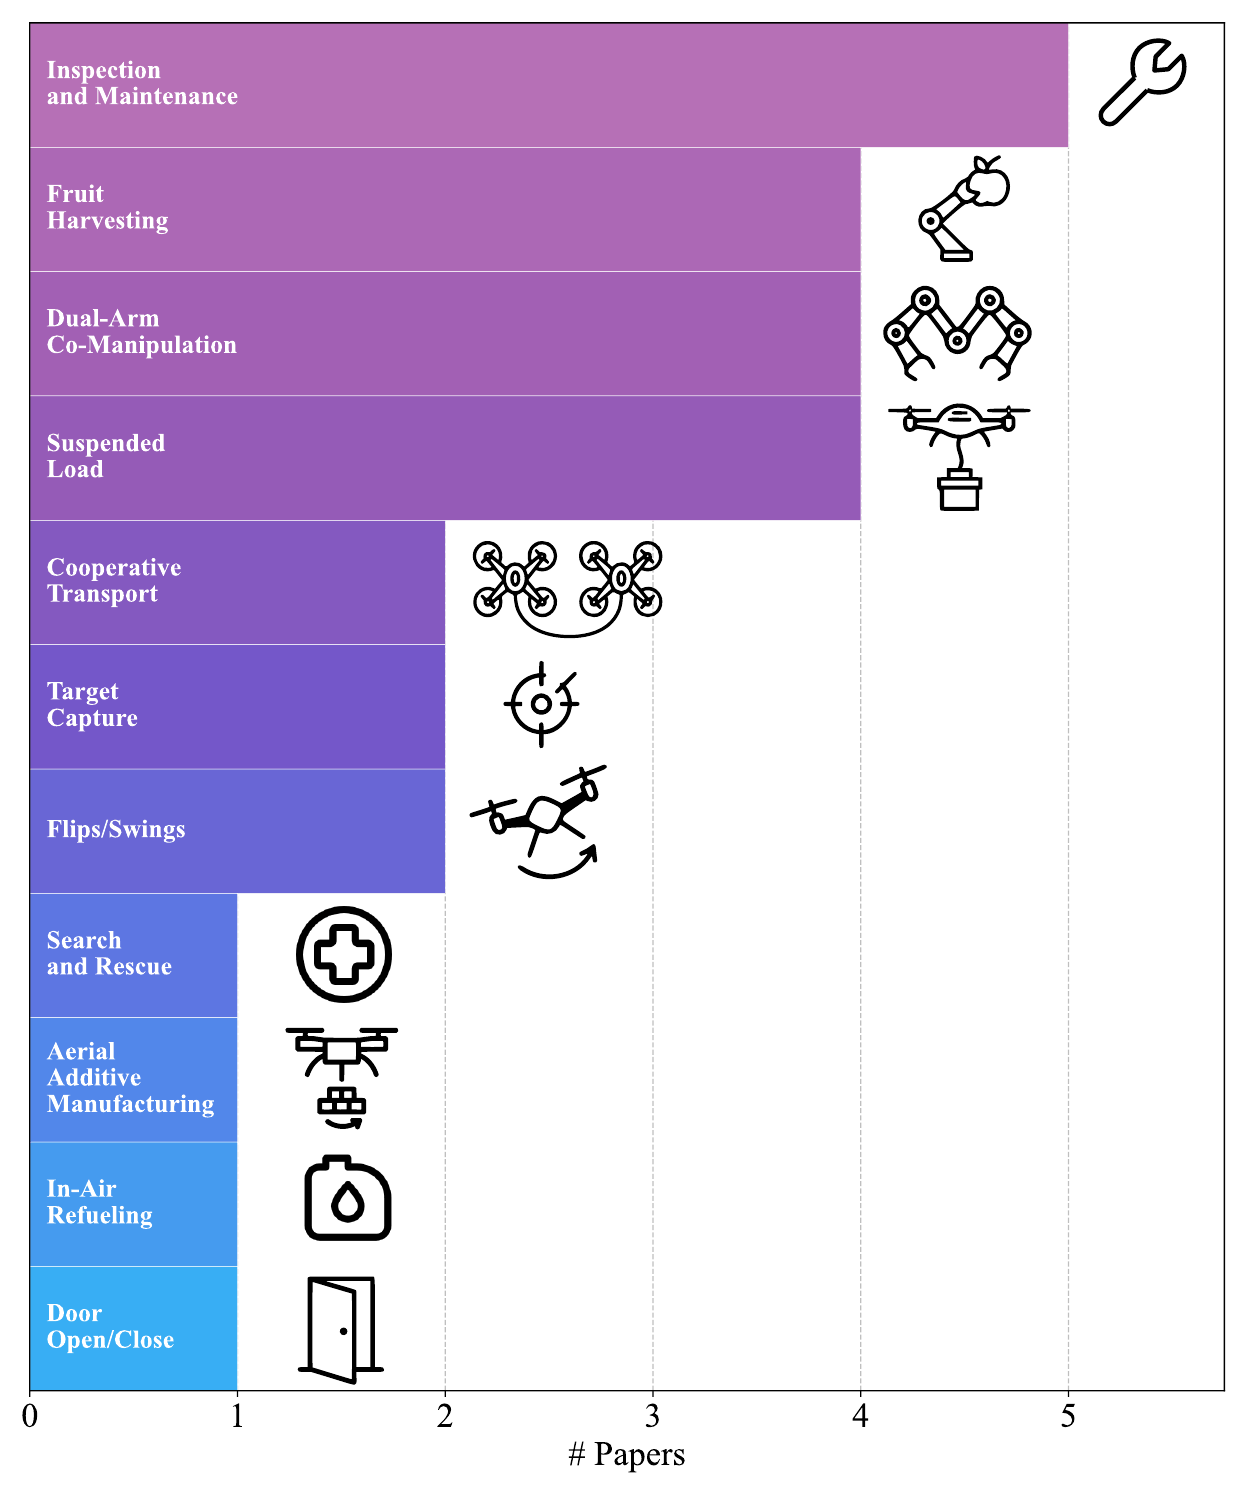
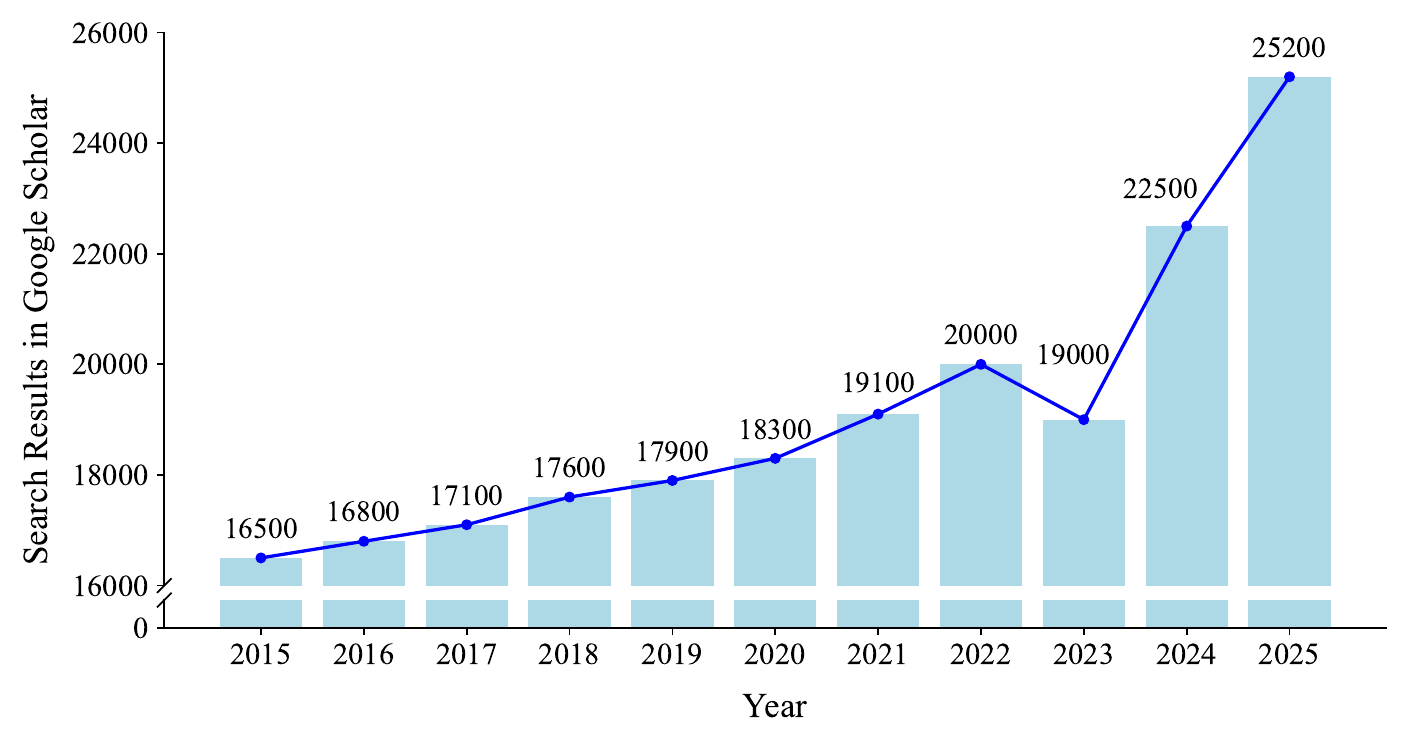
Bar chart of papers per real-world application of aerial manipulation systems, led by inspection and maintenance

Machine learning for aerial manipulation

Research Assistant · Robotics, Mechatronics, and Automation Laboratory (RMAL), TMU, with Dr. Farrokh Janabi-Sharifi · May 2025 – May 2026

Survey paper

Machine Learning in Aerial Manipulation: A Survey

Shayaan Shaikh, Niloufar Amiri, Shayan Sepahvand, Farrokh Janabi-Sharifi

Robotics and Autonomous Systems Under review

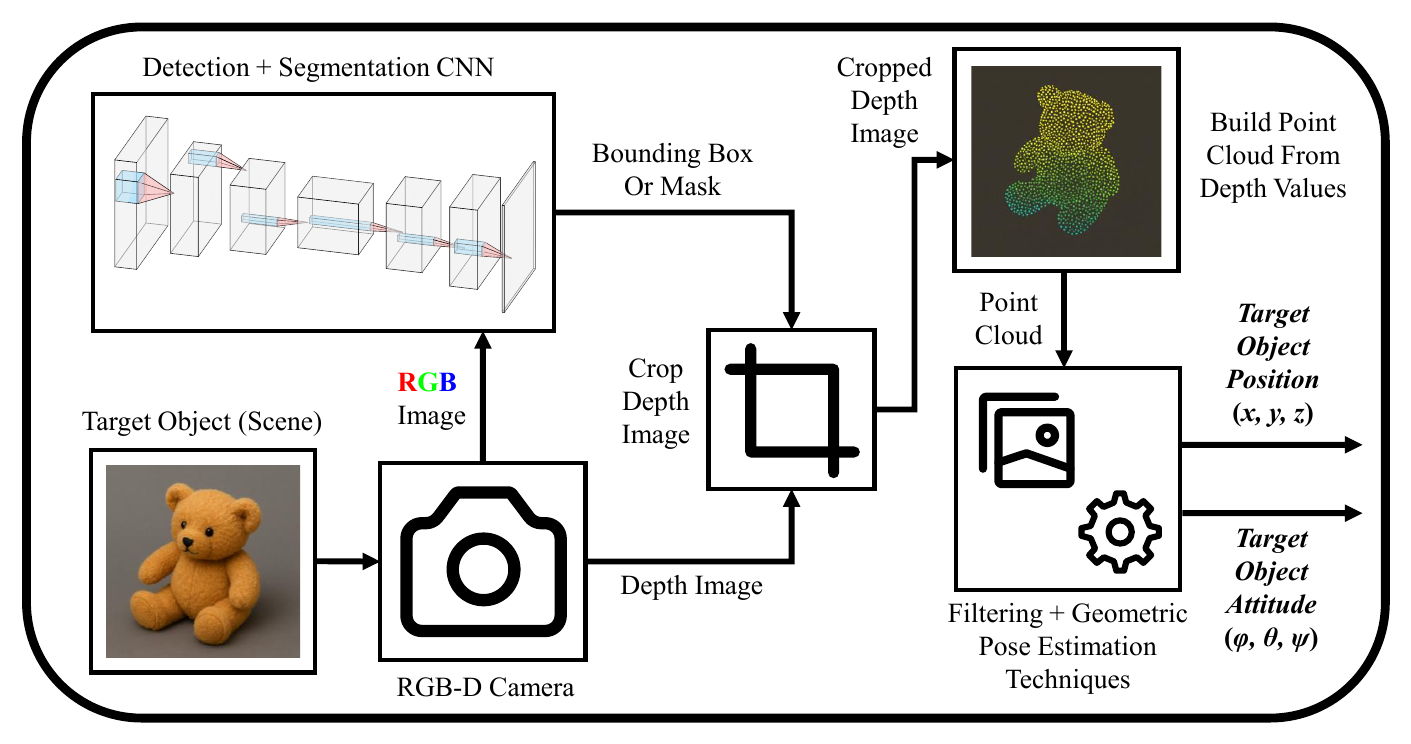
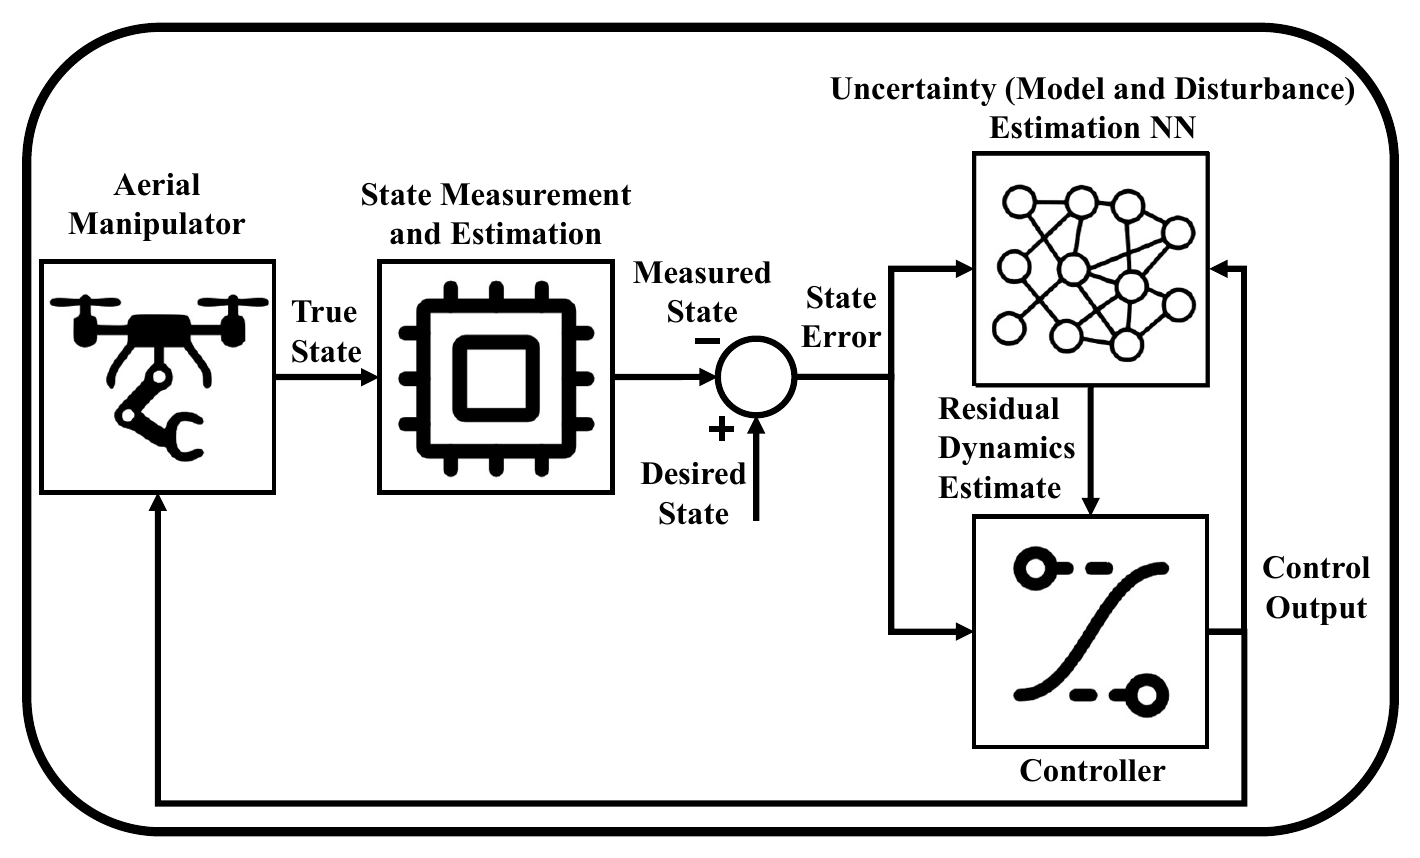
No earlier survey focused on learning for aerial manipulation, even as its use grows quickly. I analyzed the perception, control, and motion planning literature to map open challenges: object detection and localization with pretrained detectors fused with depth, system identification of unmanned aerial vehicle (UAV) and manipulator dynamics, and learning-augmented model predictive control and reinforcement learning.

Space debris tracking with star trackers

Research Assistant · Space Avionics and Instrumentation Laboratory (SAIL), TMU, with Dr. John Enright · May – Sep 2024

Conference presentation

Space Debris Monitoring Using Star Trackers

Shayaan Shaikh, John Enright

CASI ASTRO 2024, Toronto

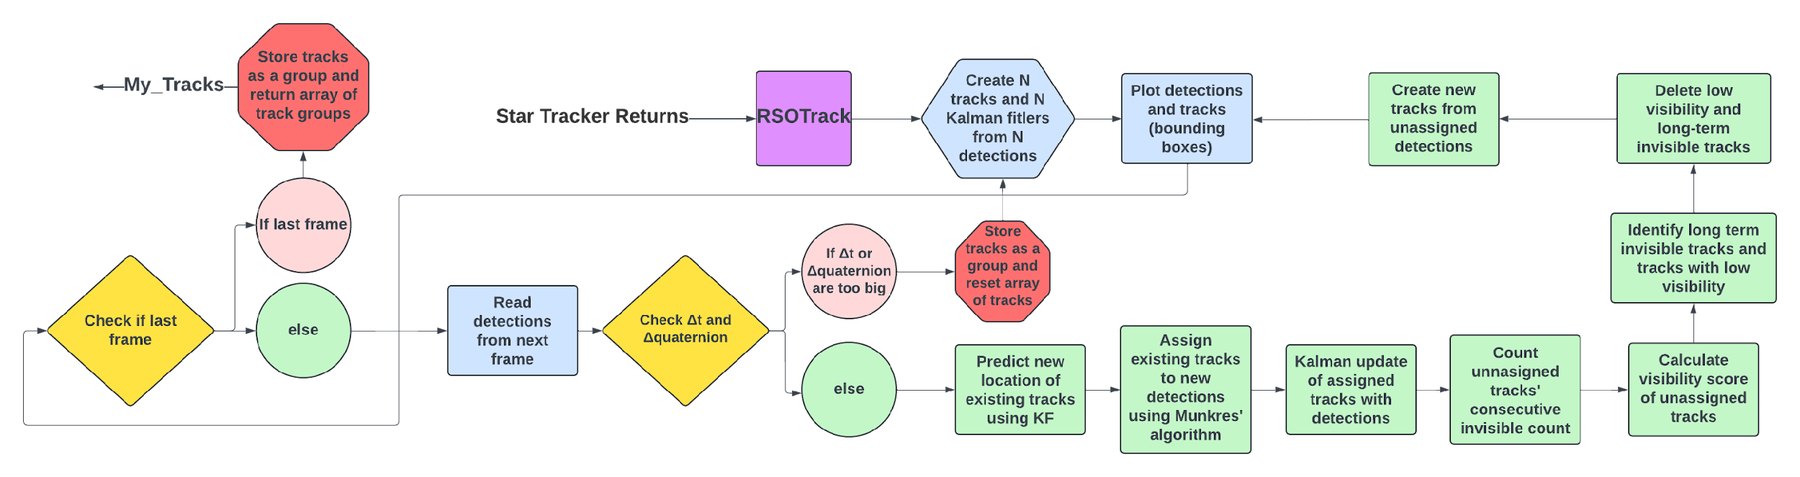
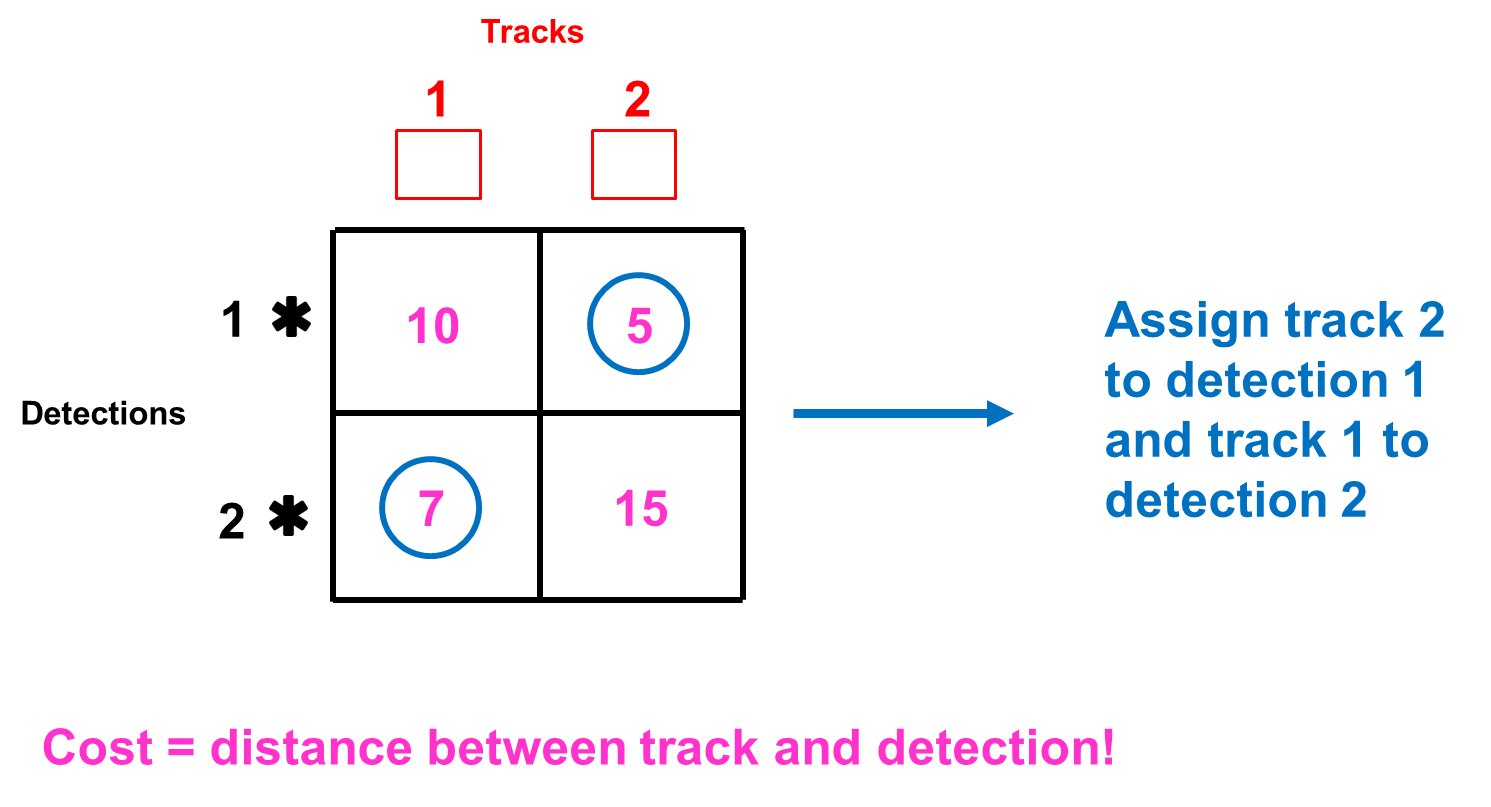
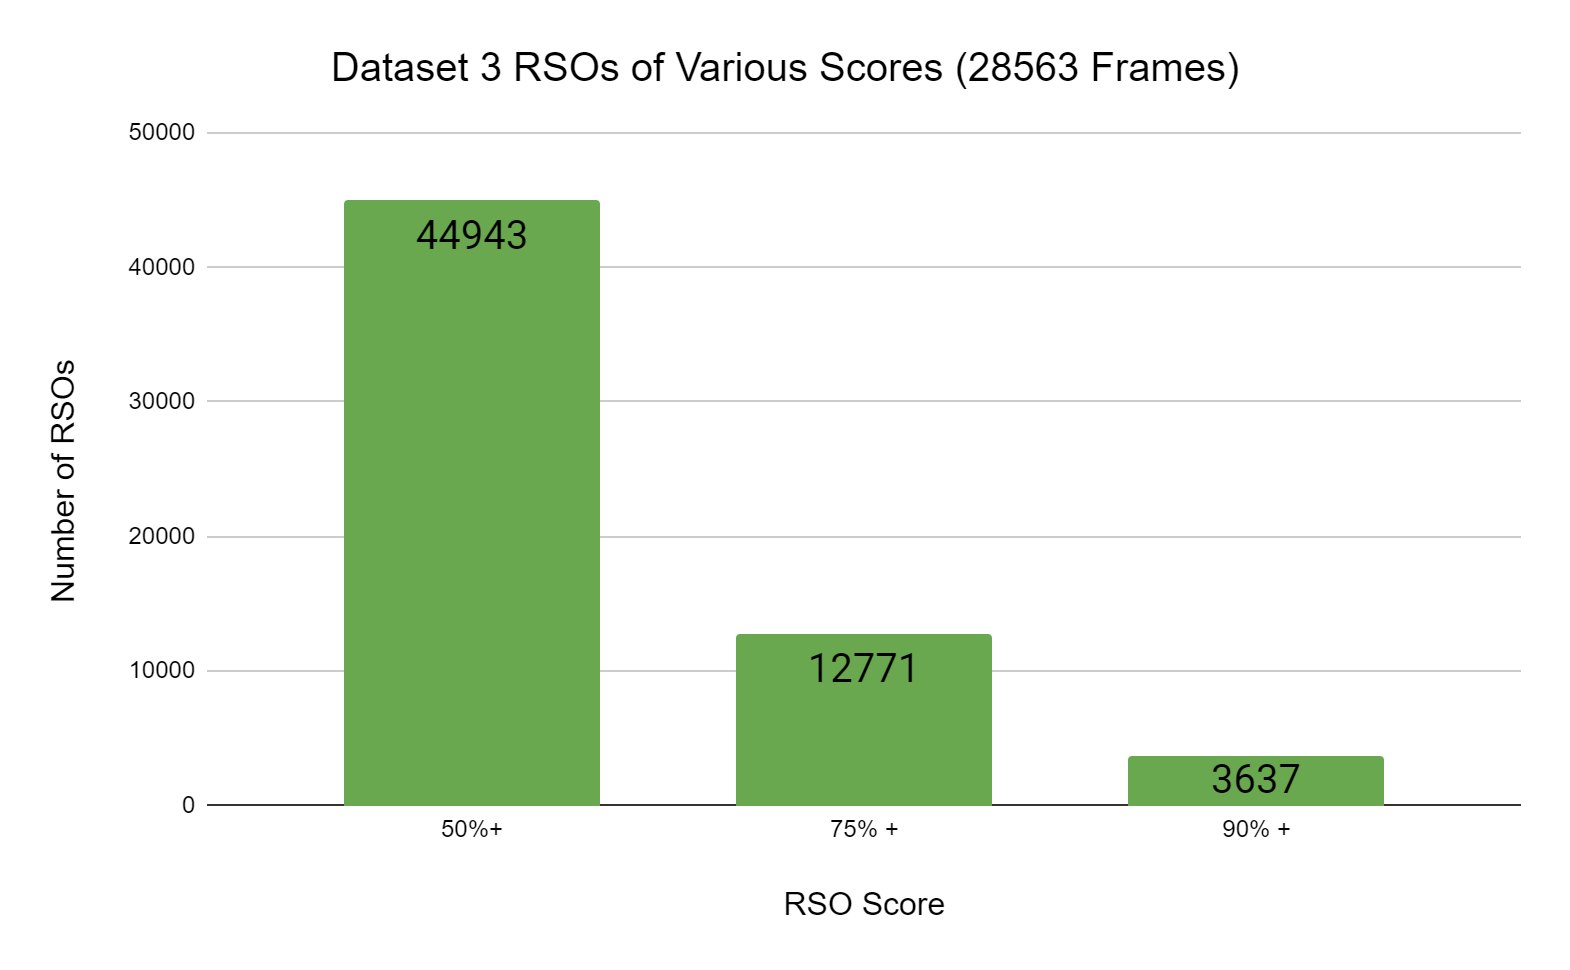
Over 100 ST-16 star trackers already in orbit can watch for debris for free. I built a lightweight multi-object tracking pipeline in MATLAB (Kalman filters with Hungarian assignment) that separates resident space objects (RSOs) from background stars, reaching about 70% multi-object tracking accuracy (MOTA) on three flight datasets from Rocket Lab and SAIL, plus a confidence score that flags likely RSOs.
Industry

MDA Space

May 2023 – May 2024

Space Robotics Intern · Brampton, ON

Worked on Canadarm3, the robotic arm for the Lunar Gateway. Tracked part procurement, design freezes, and prototype development against Canadian Space Agency deliverables, helped meet preliminary design review (PDR) exit requirements, and built a virtual reality (VR) simulator of Canadarm2 capturing a free-flyer at the International Space Station. Budgeting for nine work packages cut deficit growth by 10%.

Collins Aerospace

May – Sep 2022

In-Service Stress Analysis Tool Update Intern · Oakville, ON

Ported a Visual Basic stress analysis tool from SEAS200 to NASTRAN while keeping beam-model accuracy, compiled a load envelope from landing requirements, verified towing-case load equations, and automated Word report generation, making stress-design reports 52% faster to produce.

Projects

Autonomous Helicopter Drilling System

Team capstone, TMU · Jan – Apr 2025

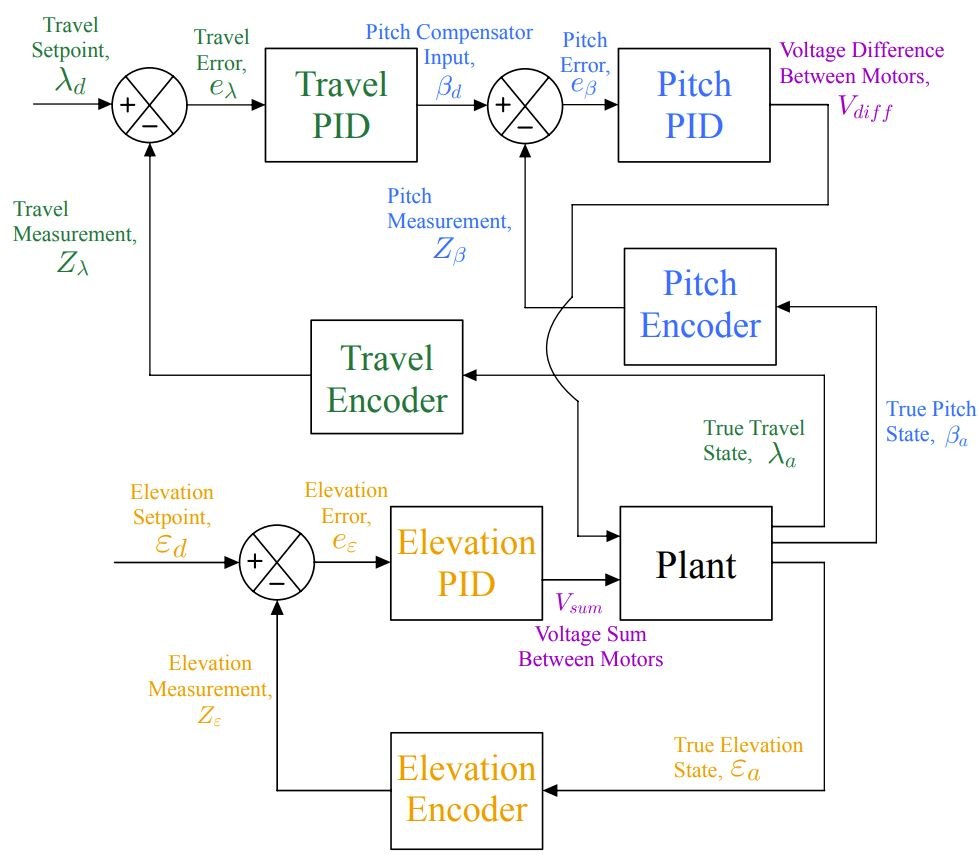
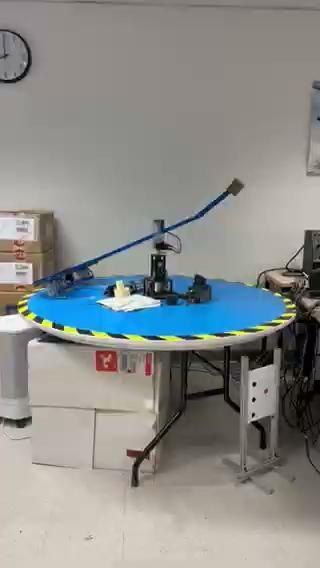
Modeled an underactuated 3-DoF Quanser helicopter from first principles and controlled it with cascaded PID loops in Simulink and on hardware, holding under 10% overshoot across its full range of motion. A Kalman filter fusing IMU and encoder data smoothed landings, a camera pipeline found drilling targets with color thresholding and blob detection, and drill control ran in C with limit-switch and IR feedback.

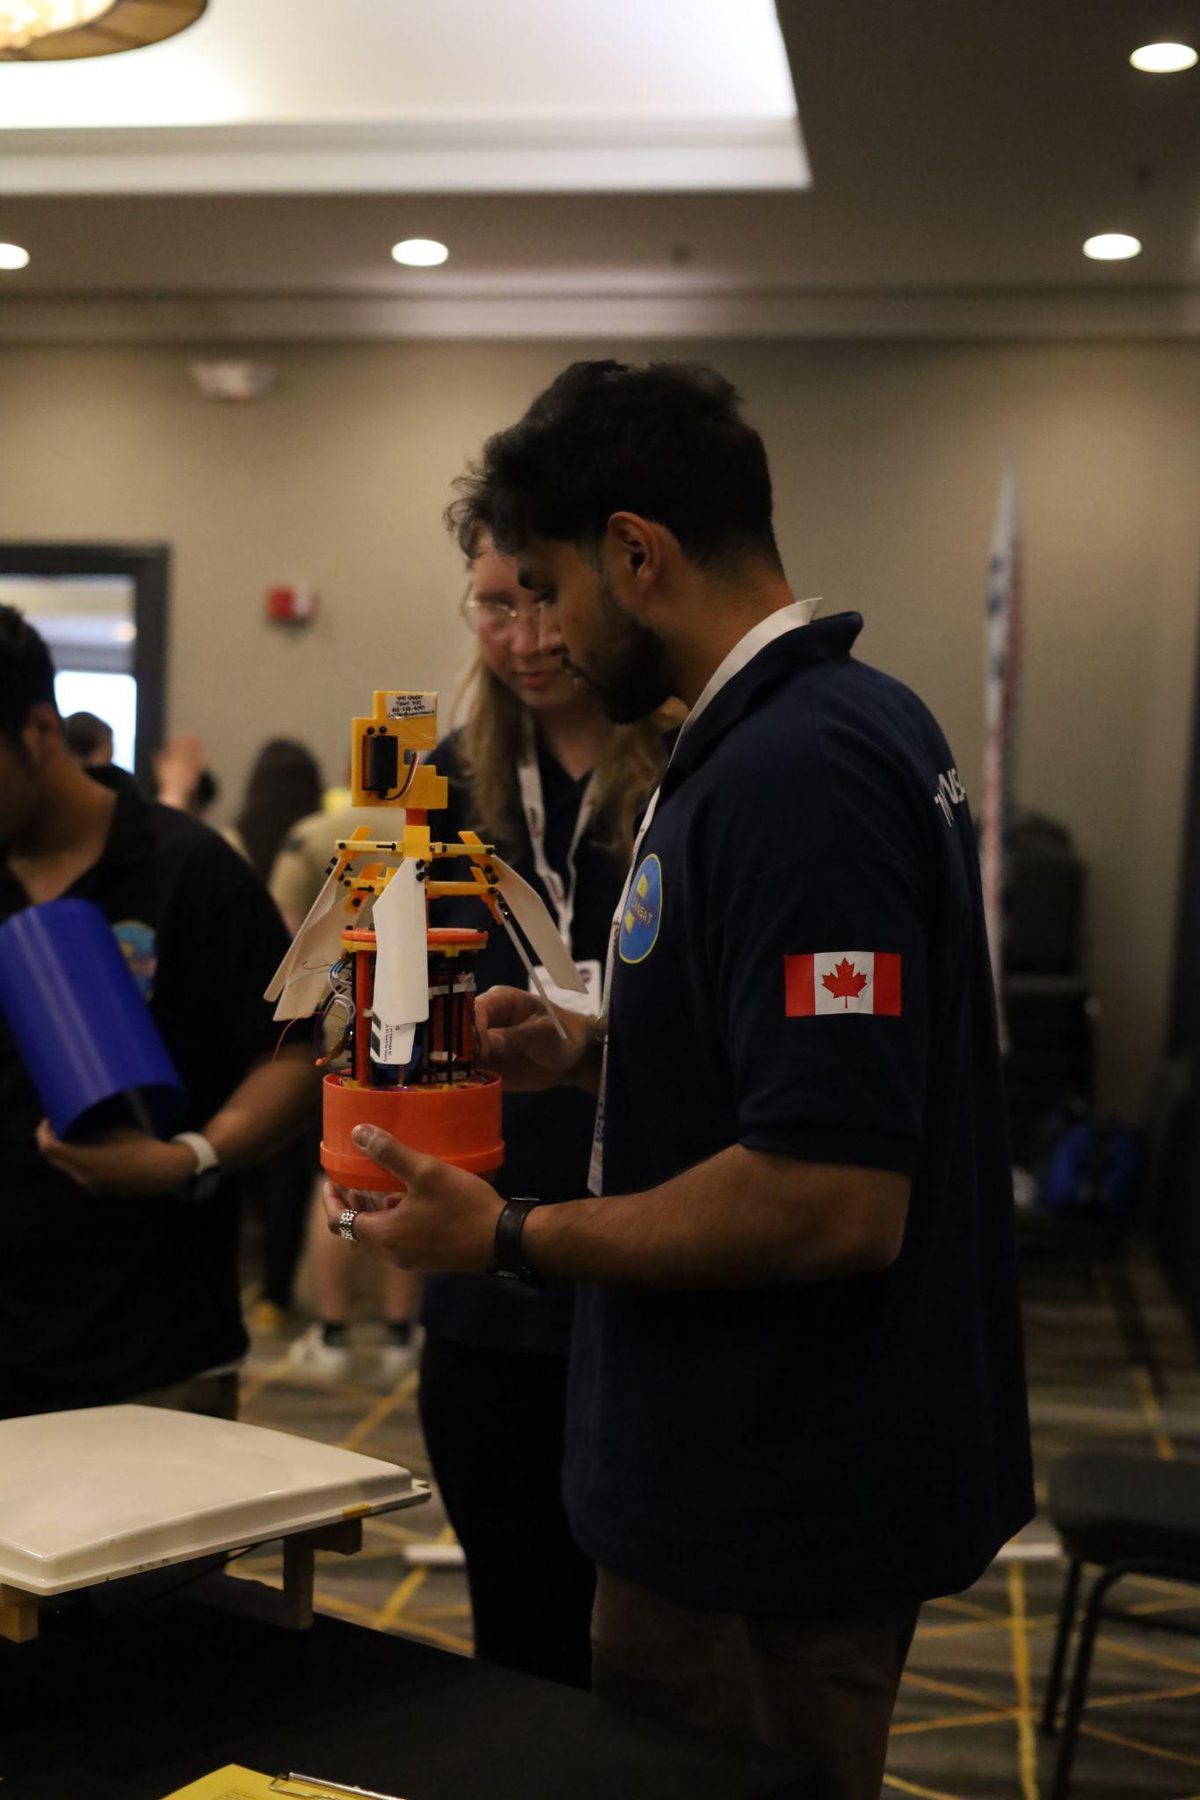
Shayaan holding the team's CanSat with its casing removed

TMU CanSat

Software Lead · Aug 2024 – Jun 2025

Led flight and ground software in Python and C/C++ for real-time telemetry (temperature, altitude, GPS) and a 2-DoF camera gimbal, prototyped on Arduino Uno and Teensy 4.1. The team received the TMU engineering faculty's Innovation Award in 2025.

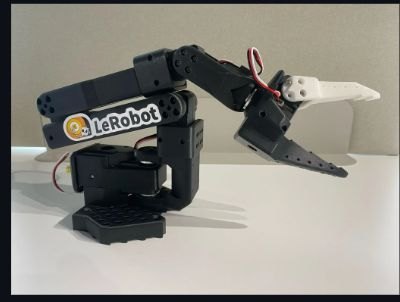
The SO-101 open-source robot arm Image: LeRobot

LeRobot SO-101 Arm

Personal project · May 2026

3D printed and assembled the open-source SO-101 arm and its teleoperation leader arm, then fine-tuned and deployed SmolVLA, a small open-source vision-language-action (VLA) model, with Hugging Face's LeRobot. Also trained a reinforcement learning policy in MuJoCo for lifting objects with the arm.

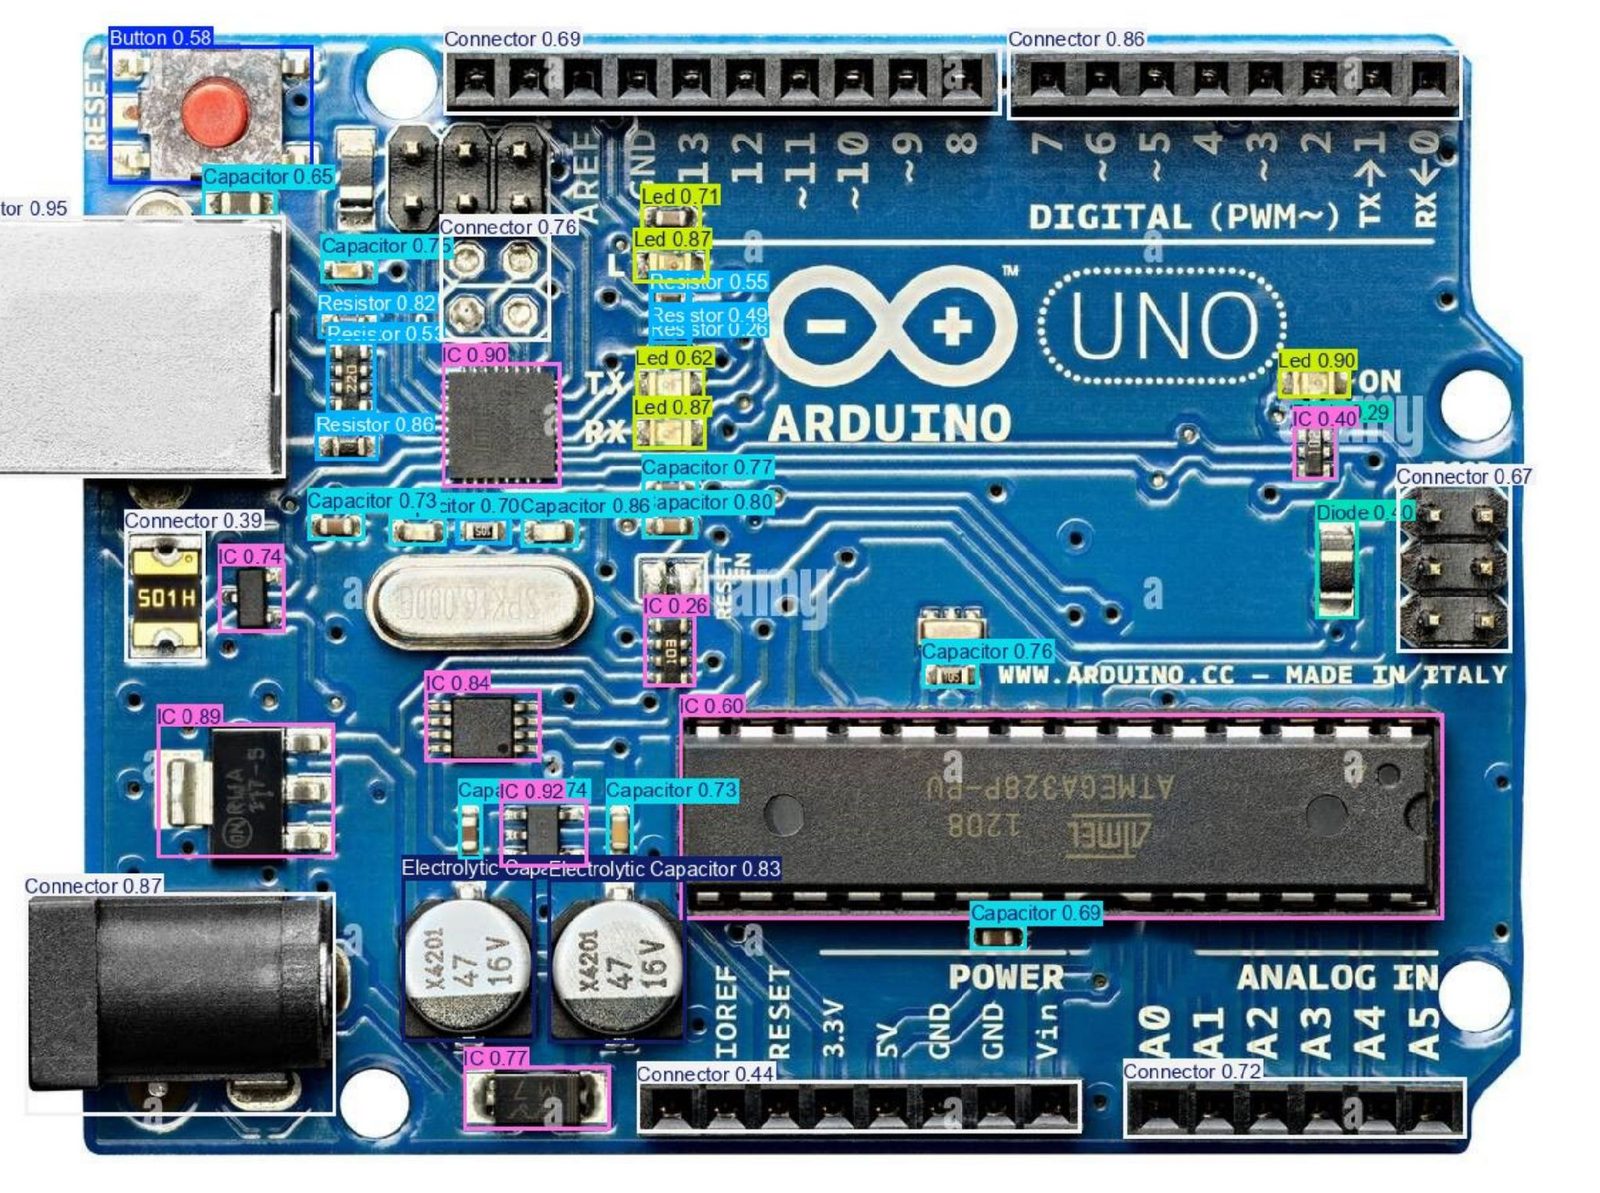
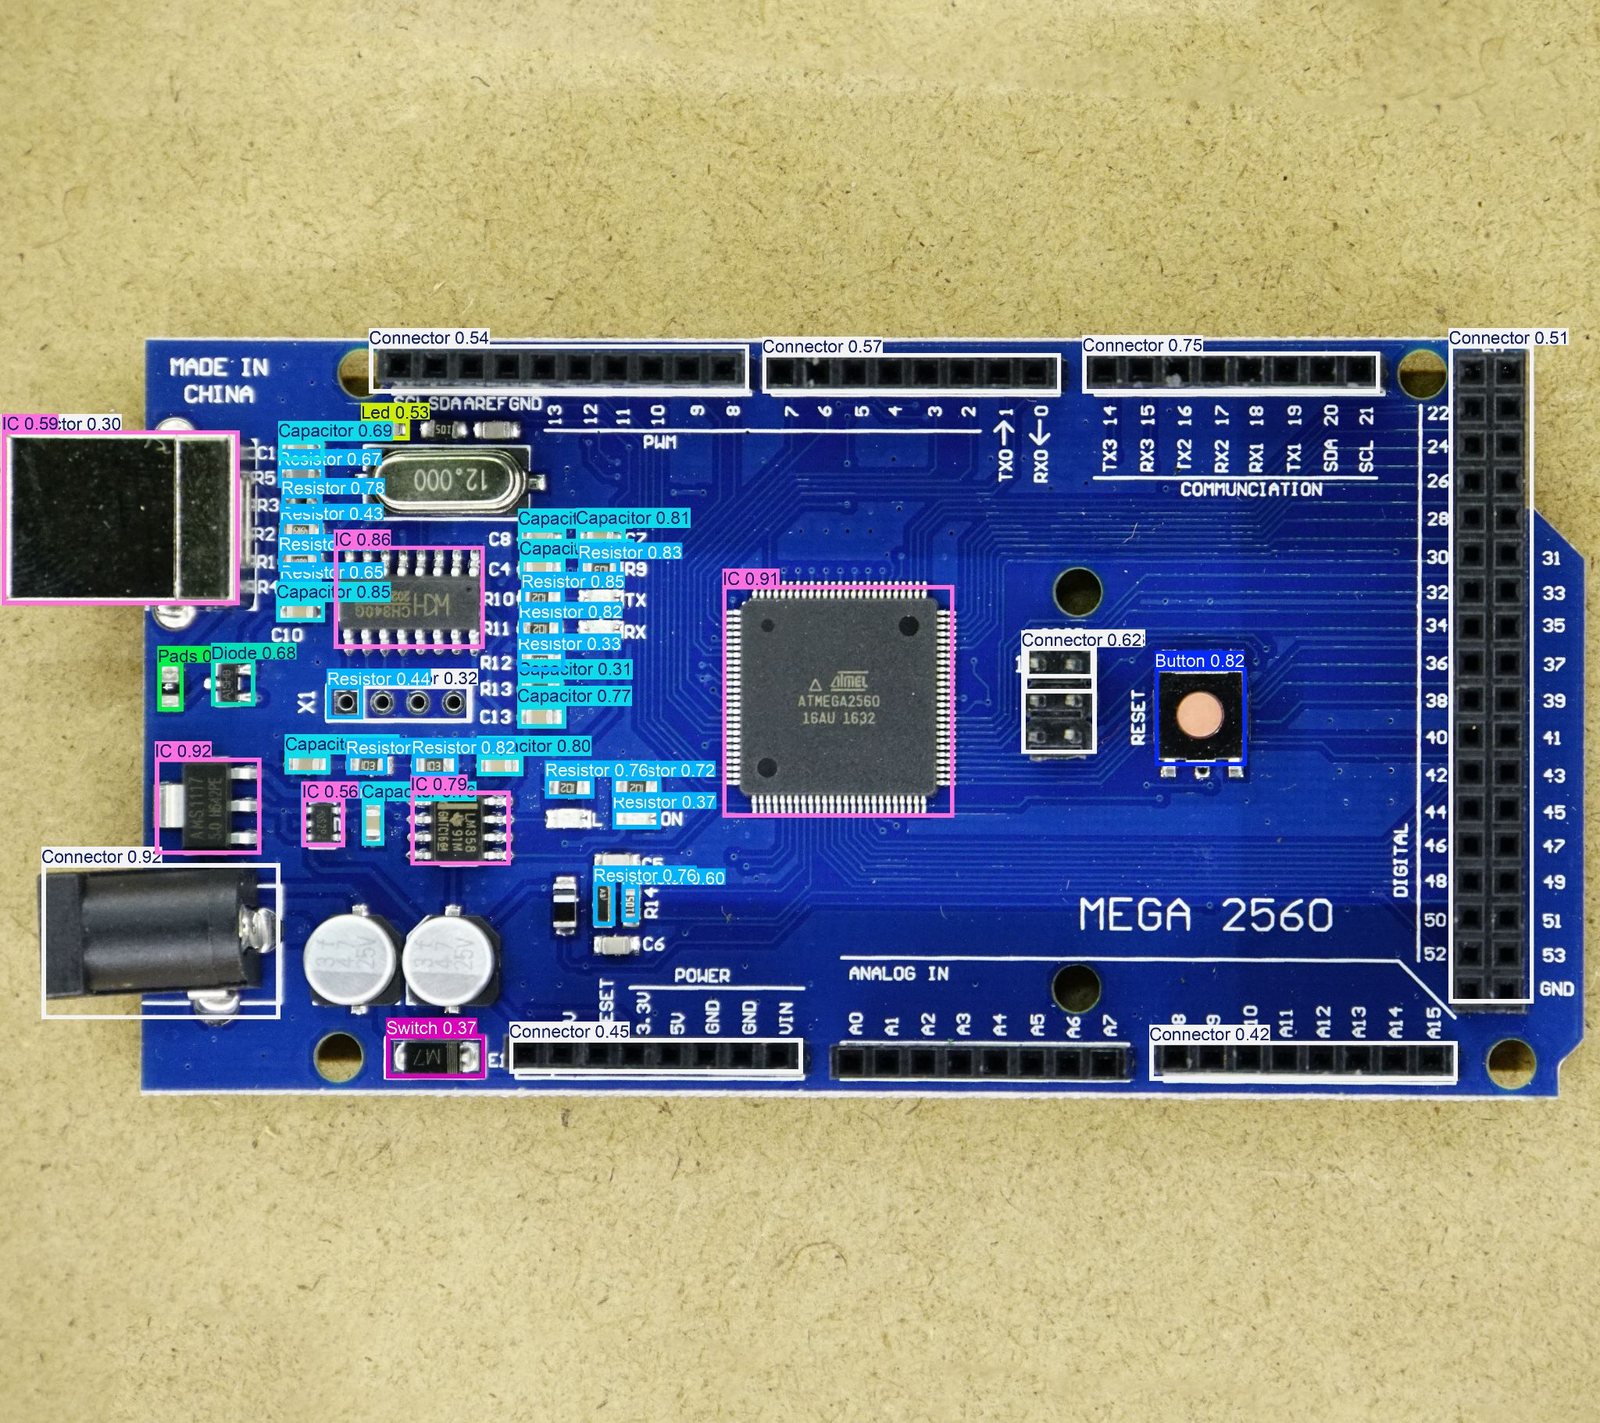
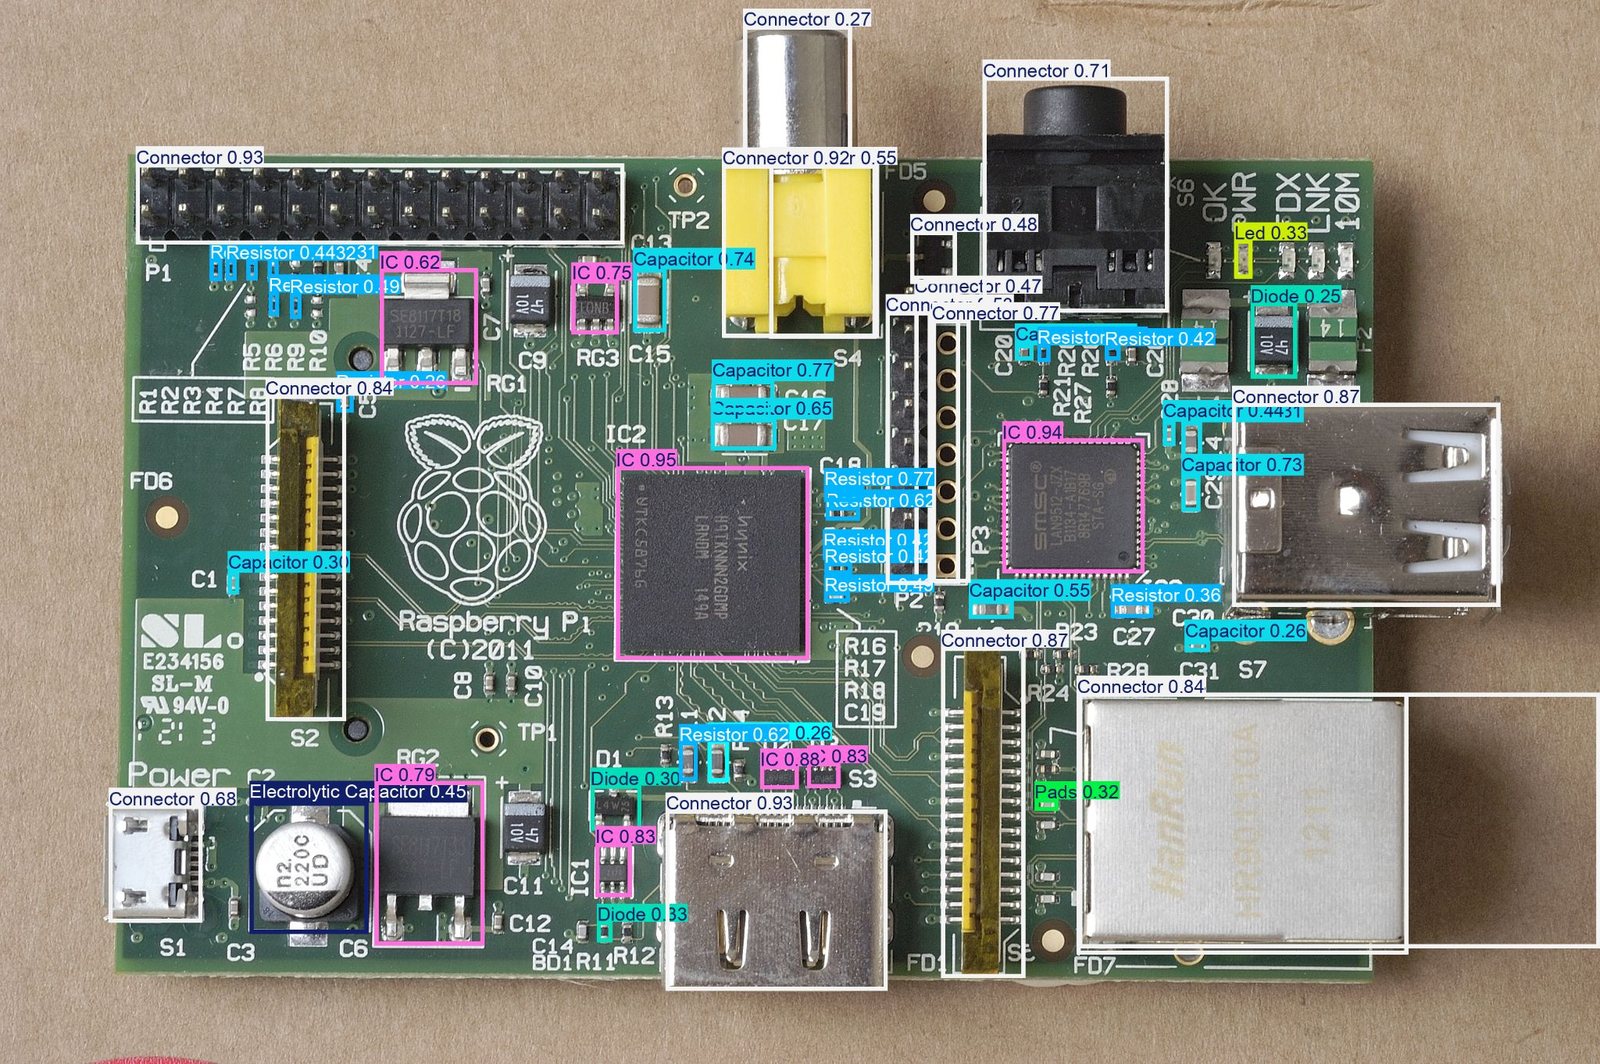
Component detections drawn over an Arduino Uno circuit board

Automated PCB Component Detection

Course project, TMU · Oct 2024

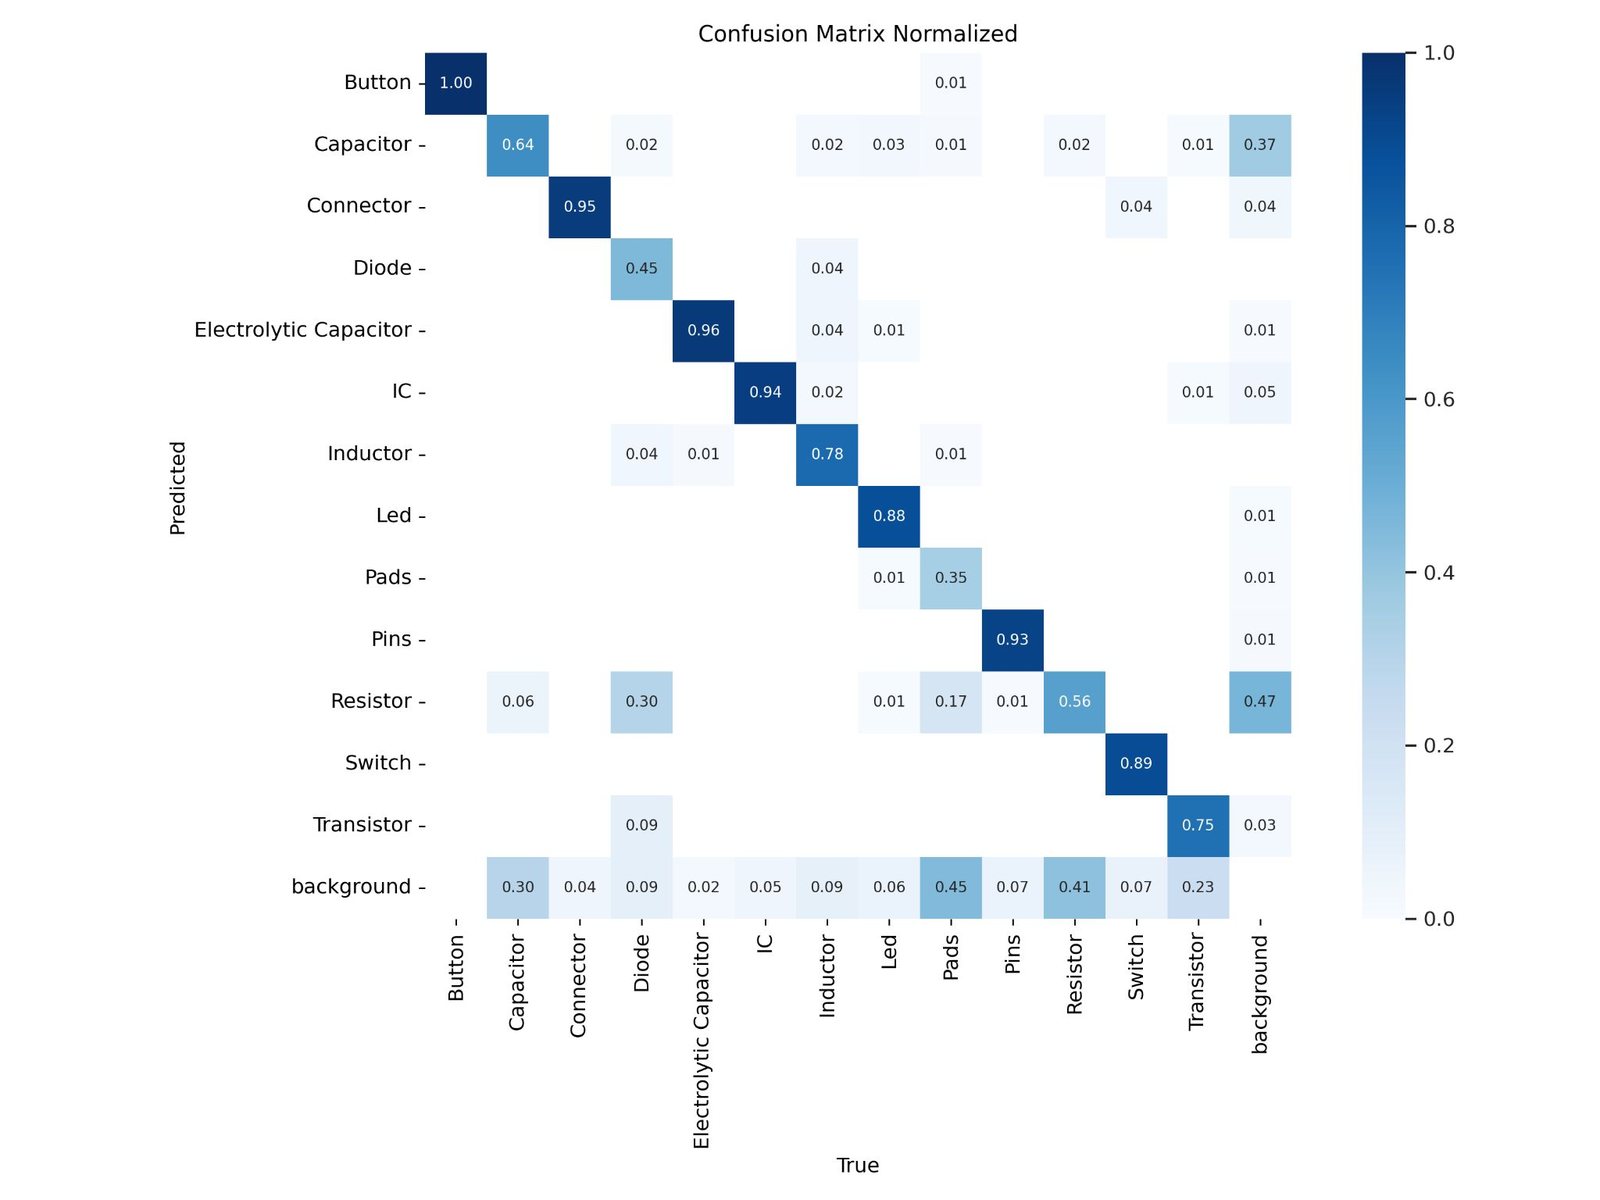
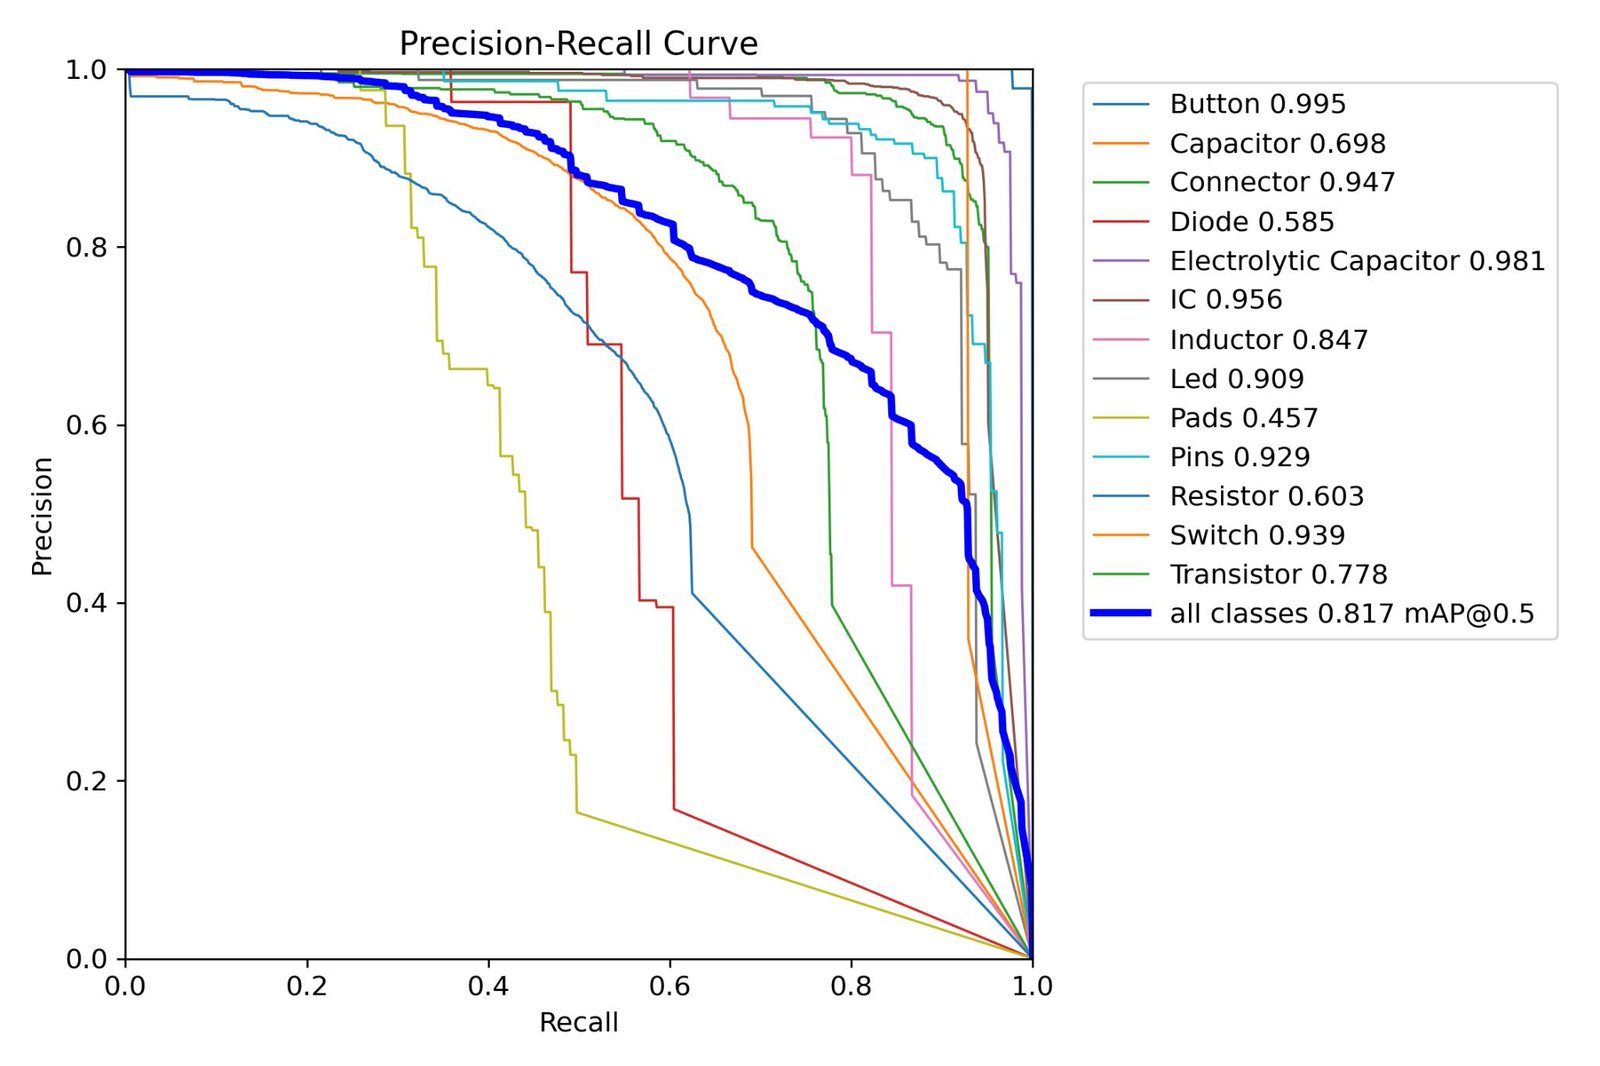
Fine-tuned a YOLOv11 detector (Ultralytics, PyTorch) to verify component placement on printed circuit boards (PCBs) across 13 component classes, reaching 81.7% mAP@50, alongside an OpenCV pipeline using image masking and edge detection.

Education

Carnegie Mellon University

2026 – 2028

MS in Robotics · Robotics Institute

Advisors: Dr. Ji Zhang and Dr. Jonathan Francis. Courses: Robot Learning, Convex Optimization, Software Engineering.

Toronto Metropolitan University

2020 – Jun 2025

B.Eng. in Aerospace Engineering, with Distinction

CGPA 4.20/4.33, ranked 2nd of 75 in the program and 5th of 738 in the faculty. Courses: Space Robotics, Machine Learning, Control Systems, Aerospace Sensors, Digital Systems, Avionics Design.

Teaching & service

  • Course development, MTE602 Introduction to RoboticsTMU · Sep – Dec 2025

    Designed the lab component for TMU's new mechatronics program: experiments on forward and inverse kinematics, pick-and-place, and programming the school's industrial manipulators.

  • Tutorial host, Flight Mechanics and Avionics & SensorsApr 2024 – Apr 2025

    Ran pre-exam review sessions for AER 416 and AER 699 over two finals seasons.

  • Chair of Orientation, TMU EngineeringDec 2023 – Dec 2024

    Led seven executive portfolios to run five days of events for over 1,500 students on a $75,000 budget, and hired and trained more than 130 orientation leaders.

  • VP Operations, TMU Aerospace Course UnionMay 2022 – May 2023

    Led the union's rebrand to TMU and a record year for merchandise revenue.

  • Conferences2022 – 2026

    Volunteer at IROS 2026; mentor and panelist at the Global Changemakers Engineering Conference (Motorola Solutions) 2024; TMU delegate to the Canadian Engineering Leadership Conference 2023 and the PEO Student Conference 2022.

Honors

  • Dennis Mock Student Leadership Award, program and faculty-wideTMU · Apr 2025
  • Innovation Award, TMU CanSatTMU Faculty of Engineering · 2025
  • Dean's Research Fund Undergraduate Research Experience AwardTMU Faculty of Engineering · 2024
  • Carl Smythe AwardTMU Faculty of Engineering · 2024
  • Ventura Nobis Consilio ("Design for the Future") AwardTMU Faculty of Engineering · 2024
  • Magellan Aerospace Richard A. Neil Memorial ScholarshipMagellan Aerospace · 2023
  • Renewable Entrance ScholarshipTMU Faculty of Engineering · 2020 – 2025